

Questo è il tuo strumento IA? Reclama oggi.
Verifica la titolarità, gestisci il profilo e sblocca funzioni di crescita.
MuJoCo is a high-performance physics simulation engine that runs directly in your browser via WebAssembly, offering realistic and interactive simulations for robotics, biomechanics, and animation. Its advanced modeling capabilities and native browser support make it an ideal choice for researchers and developers seeking accurate and accessible physics simulations.
Descrizione
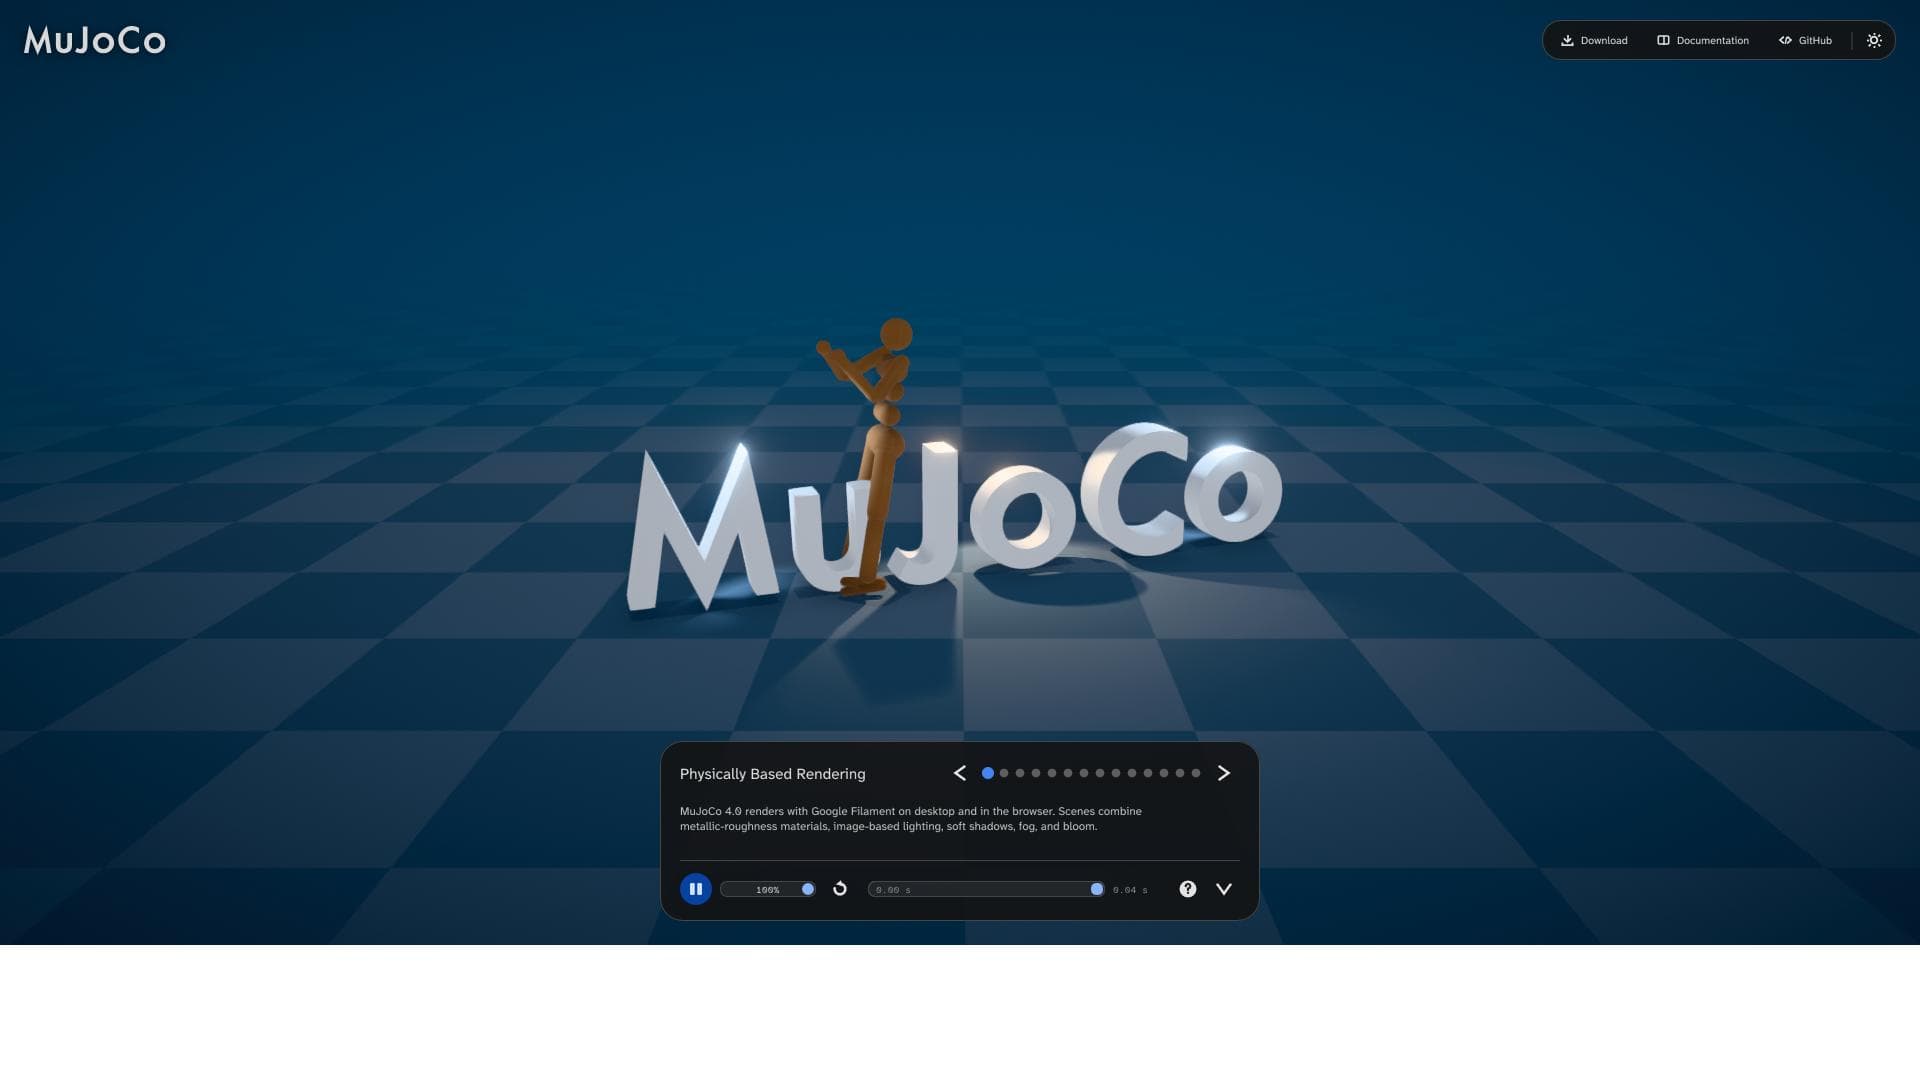
MuJoCo 4 is a major update to Google DeepMind's open-source physics engine. It adds a modular 3D Studio, improved deformable-body simulation, and better handling of fast collisions. Explore models in your browser or build custom viewers.
Descrizione dettagliata
MuJoCo (Multi-Joint dynamics with Contact) is a cutting-edge physics simulation engine designed to provide high-fidelity and high-performance modeling of physical systems. Its core purpose is to enable realistic and interactive physics simulations that can be run natively in web browsers through WebAssembly technology, eliminating the need for complex installations or specialized hardware. This makes MuJoCo an ideal platform for researchers, developers, and educators working in robotics, biomechanics, computer graphics, and animation who require precise and efficient physics modeling. MuJoCo's advanced engine simulates multi-joint dynamics with contact and friction, allowing users to create detailed and accurate virtual environments that mimic real-world physical interactions. One of MuJoCo's standout features is its interactive physics showcase, which demonstrates the engine's capabilities directly in the browser. This showcase highlights the engine's ability to handle complex simulations involving articulated bodies, collision detection, and dynamic responses with remarkable speed and accuracy. The use of WebAssembly ensures that these simulations run smoothly and responsively without relying on server-side processing, providing an immersive and accessible user experience. Additionally, MuJoCo supports a wide range of applications including robotics simulations where precise control and feedback are critical, biomechanics studies that require modeling of human or animal movement, and graphics or animation projects that benefit from physically plausible motion and interactions. MuJoCo is particularly well-suited for robotics researchers and engineers who need to test control algorithms and robot designs in a virtual environment before deploying them in the real world. Its accurate contact modeling and dynamic simulation capabilities allow for realistic testing of manipulation, locomotion, and interaction tasks. Biomechanics researchers can use MuJoCo to simulate musculoskeletal systems and study movement dynamics under various conditions. In the realm of computer graphics and animation, MuJoCo enables creators to produce lifelike animations driven by physics rather than manual keyframing, enhancing realism and reducing production time. Regarding pricing, MuJoCo offers a tiered licensing model that caters to different user needs, including academic, commercial, and personal use. While specific pricing details may vary and should be checked on the official website, MuJoCo typically provides free or discounted licenses for educational and research purposes, making it accessible to students and academics. Commercial licenses are available for enterprises and developers who require full capabilities and support for production environments. This flexible pricing approach ensures that MuJoCo can be adopted by a broad spectrum of users without prohibitive costs. When compared to alternative physics engines such as Bullet, ODE, or PhysX, MuJoCo stands out for its balance of speed, accuracy, and ease of use, especially in scenarios involving complex contact dynamics and articulated bodies. Its native browser support via WebAssembly is a unique advantage, enabling instant access and interaction without installation overhead. While other engines may offer broader feature sets or integration with game development platforms, MuJoCo’s specialization in robotics and biomechanics simulations provides a niche focus that is highly valued in those communities. However, potential users should consider some limitations. MuJoCo's primary focus on articulated rigid-body dynamics means it may not be the best choice for fluid dynamics or soft-body simulations. Additionally, while the browser-based showcase is impressive, fully leveraging MuJoCo’s capabilities often requires familiarity with its XML model specification and programming interfaces, which can present a learning curve for newcomers. Lastly, integration with some third-party tools or platforms may require additional development effort. In summary, MuJoCo is a powerful and versatile physics simulation engine that excels in delivering accurate, high-performance simulations for robotics, biomechanics, and animation applications. Its browser-native WebAssembly implementation makes it uniquely accessible, while its advanced modeling capabilities meet the demands of researchers and developers seeking realistic physical interactions. With flexible licensing and a strong focus on specialized use cases, MuJoCo is a valuable tool for those requiring precise and interactive physics simulations.
Funzioni dello strumento
- Advanced physics simulation engine
- Interactive physics showcase
- Runs natively in browser via WebAssembly
- High-performance and accurate physics modeling
- Supports robotics and biomechanics simulations
- Enables realistic graphics and animation
Descrizione
MuJoCo is a high-performance physics simulation engine that runs directly in your browser via WebAssembly, offering realistic and interactive simulations for robotics, biomechanics, and animation. Its advanced modeling capabilities and native browser support make it an ideal choice for researchers and developers seeking accurate and accessible physics simulations.
MuJoCo 4 is a major update to Google DeepMind's open-source physics engine. It adds a modular 3D Studio, improved deformable-body simulation, and better handling of fast collisions. Explore models in your browser or build custom viewers.
Descrizione dettagliata
MuJoCo (Multi-Joint dynamics with Contact) is a cutting-edge physics simulation engine designed to provide high-fidelity and high-performance modeling of physical systems. Its core purpose is to enable realistic and interactive physics simulations that can be run natively in web browsers through WebAssembly technology, eliminating the need for complex installations or specialized hardware. This makes MuJoCo an ideal platform for researchers, developers, and educators working in robotics, biomechanics, computer graphics, and animation who require precise and efficient physics modeling. MuJoCo's advanced engine simulates multi-joint dynamics with contact and friction, allowing users to create detailed and accurate virtual environments that mimic real-world physical interactions. One of MuJoCo's standout features is its interactive physics showcase, which demonstrates the engine's capabilities directly in the browser. This showcase highlights the engine's ability to handle complex simulations involving articulated bodies, collision detection, and dynamic responses with remarkable speed and accuracy. The use of WebAssembly ensures that these simulations run smoothly and responsively without relying on server-side processing, providing an immersive and accessible user experience. Additionally, MuJoCo supports a wide range of applications including robotics simulations where precise control and feedback are critical, biomechanics studies that require modeling of human or animal movement, and graphics or animation projects that benefit from physically plausible motion and interactions. MuJoCo is particularly well-suited for robotics researchers and engineers who need to test control algorithms and robot designs in a virtual environment before deploying them in the real world. Its accurate contact modeling and dynamic simulation capabilities allow for realistic testing of manipulation, locomotion, and interaction tasks. Biomechanics researchers can use MuJoCo to simulate musculoskeletal systems and study movement dynamics under various conditions. In the realm of computer graphics and animation, MuJoCo enables creators to produce lifelike animations driven by physics rather than manual keyframing, enhancing realism and reducing production time. Regarding pricing, MuJoCo offers a tiered licensing model that caters to different user needs, including academic, commercial, and personal use. While specific pricing details may vary and should be checked on the official website, MuJoCo typically provides free or discounted licenses for educational and research purposes, making it accessible to students and academics. Commercial licenses are available for enterprises and developers who require full capabilities and support for production environments. This flexible pricing approach ensures that MuJoCo can be adopted by a broad spectrum of users without prohibitive costs. When compared to alternative physics engines such as Bullet, ODE, or PhysX, MuJoCo stands out for its balance of speed, accuracy, and ease of use, especially in scenarios involving complex contact dynamics and articulated bodies. Its native browser support via WebAssembly is a unique advantage, enabling instant access and interaction without installation overhead. While other engines may offer broader feature sets or integration with game development platforms, MuJoCo’s specialization in robotics and biomechanics simulations provides a niche focus that is highly valued in those communities. However, potential users should consider some limitations. MuJoCo's primary focus on articulated rigid-body dynamics means it may not be the best choice for fluid dynamics or soft-body simulations. Additionally, while the browser-based showcase is impressive, fully leveraging MuJoCo’s capabilities often requires familiarity with its XML model specification and programming interfaces, which can present a learning curve for newcomers. Lastly, integration with some third-party tools or platforms may require additional development effort. In summary, MuJoCo is a powerful and versatile physics simulation engine that excels in delivering accurate, high-performance simulations for robotics, biomechanics, and animation applications. Its browser-native WebAssembly implementation makes it uniquely accessible, while its advanced modeling capabilities meet the demands of researchers and developers seeking realistic physical interactions. With flexible licensing and a strong focus on specialized use cases, MuJoCo is a valuable tool for those requiring precise and interactive physics simulations.
Domande frequenti
What is MuJoCo?
MuJoCo is an advanced physics simulation engine designed to provide high-fidelity modeling of multi-joint dynamics with contact and friction. It enables realistic and interactive physics simulations primarily used in robotics, biomechanics, graphics, and animation.
How much does MuJoCo cost?
MuJoCo offers tiered licensing options including free or discounted licenses for academic and research use, as well as commercial licenses for enterprise and production environments. Pricing details are available on the official MuJoCo website.
Who is MuJoCo best for?
MuJoCo is best suited for robotics researchers, engineers, biomechanics scientists, and computer graphics professionals who require accurate and efficient physics simulations for testing, analysis, or animation.
What are the main features of MuJoCo?
Key features include an advanced physics engine for multi-joint dynamics, interactive physics showcases running natively in browsers via WebAssembly, high-performance and accurate physics modeling, support for robotics and biomechanics simulations, and capabilities for realistic graphics and animation.
Does MuJoCo offer a free trial?
MuJoCo provides free access or discounted licenses for academic and research purposes, which can be considered a form of trial. For commercial use, users should check the official website for any trial or evaluation options.
What integrations does MuJoCo support?
MuJoCo primarily integrates through its XML model specification and programming APIs. While it does not have extensive out-of-the-box integrations with third-party platforms, it can be incorporated into custom workflows and software environments with development effort.
How does MuJoCo work?
MuJoCo simulates physical systems by modeling multi-joint dynamics with precise contact and friction calculations. It runs simulations efficiently using native browser support through WebAssembly, allowing interactive physics experiences without additional software installation.
Social
Usa lo strumentoRecensioni
Ancora nessuna recensione. Sii il primo a condividere la tua esperienza.